- Home
- A-Z Catalogue
- Products
- Valves
- Cetop
- Manual Directional Valves
- Proportional Valves
- Poppet Valves
- High-Speed Linear Servo Valves
- All High-Speed Linear Servo Valves
- Cetop 10 (NG32) Two Stage Type High Speed Linear Servo Valves – LSVHG-10
- Cetop 10 (NG32) Two Stage Type High Speed Linear Servo Valves – LSVHG-10 (With Fail-Safe)
- Cetop 8 (NG25) Two Stage Type High Speed Linear Servo Valves – LSVHG-06
- Cetop 8 (NG25) Two Stage Type High Speed Linear Servo Valves – LSVHG-06 (With Fail-Safe)
- Cetop 7 (NG16) Two Stage Type High Speed Linear Servo Valves – LSVHG-04
- Cetop 7 (NG16) Two Stage Type High Speed Linear Servo Valves – LSVHG-04 (With Fail-Safe)
- Cetop 5 (NG10) Direct Type High Speed Linear Servo Valves – LSVG-03
- Cetop 5 (NG10) OBE Type Direct Operated Linear Servo Valves – LSVG-03-EH
- Cetop 3 (NG6) OBE Type Direct Operated Linear Servo Valves – LSVG-01-EH
- Pumps
- Pressure control
- Flow Control Valves
- Pressure Control Valves
- All Pressure Control Valves
- Brake Valves
- Direct Relief Valve
- Low Noise Solenoid Controlled Relief Valves
- Low Noise Pilot Operated Relief Valves
- Pilot Operated Relief Valves
- Pressure reducing and relieving valves
- Pressure reducing and check valves
- Pressure control valves
- Remote Control Relief Valves
- Solenoid Controlled Relief Valves – BSG
- Solenoid Controlled Relief Valves – BST
- Unloading relief valves
- Check valves
- Environmental
- Valves
- Hydraulic Systems
- Power pack
- About Us
- Contact
- Blog
7 Tips for Choosing the Right DC Motor Drive?
Choosing the right Dc Motor Drive is rarely just a matter of matching voltage and horsepower. The drive must suit the motor, load, operating cycle, and working environment. A conveyor moving steady boxes needs different control from a hoist facing sudden torque changes. Small details matter. Measure the motor’s rated voltage, current, speed, and starting torque before comparing products. Then examine acceleration, braking, reversing, and speed regulation requirements. A drive that works smoothly in a test room may struggle beside heat, dust, or electrical noise.
The seven tips in this guide focus on practical selection decisions that engineers and maintenance teams often face. They cover motor compatibility, control methods, feedback options, protection functions, thermal performance, installation limits, and supplier support. Reliable datasheets should explain continuous and peak current ratings clearly. Application notes can reveal limitations that product advertisements overlook. Ask whether the Dc Motor Drive supports your feedback device, communication system, and required safety functions. Also check enclosure ratings, cooling space, and service access before purchase. Measure twice.
A common mistake is choosing by maximum power alone. Another is ignoring the load during starting. These oversights can cause overheating, unstable speed, nuisance trips, or shortened motor life. Real testing remains valuable. Record current, temperature, noise, and response during realistic operating cycles. No selection method is perfect. Still, careful comparison and documented testing can reduce risk, control costs, and produce a more dependable motor system.
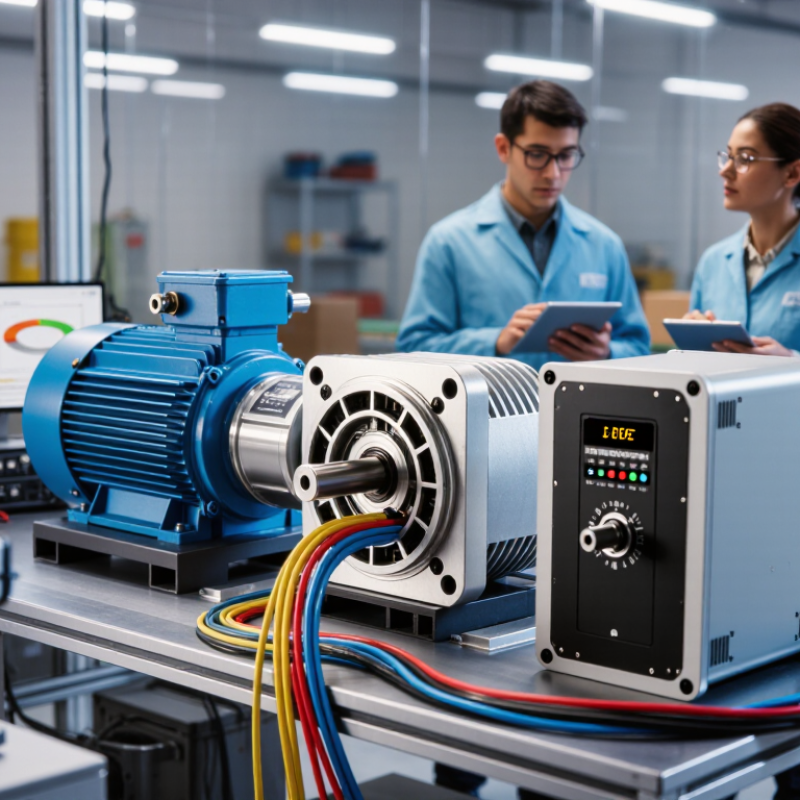
Table of Contents [Hide]
Understanding DC Motor Drives and Their Main Functions
7 Tips for Choosing the Right DC Motor Drive
A DC motor drive does more than adjust speed. It converts incoming power, regulates armature voltage, controls torque, manages direction, and can provide braking. The International Energy Agency estimates that electric motor systems use about 53% of global electricity. Its energy-efficiency analysis also indicates potential savings of 20–30% through better motor systems. That makes drive selection a practical energy decision, not just a purchasing task.
Check these seven points: match rated voltage and current; confirm starting and continuous torque; select the required speed-control range; choose open-loop or feedback control; verify duty cycle and heat dissipation; review overload and fault protection; and inspect maintenance access. A drive rated for 10 amps may still fail when a conveyor starts fully loaded. Peak current matters. So does the enclosure near dust, moisture, or vibration. A commissioning engineer should measure actual load behavior, not trust a neat spreadsheet alone. Real machines are less polite.
The drive’s main functions should fit the application. A feedback system can hold speed when load changes, while a simpler controller may suit steady operation. Regenerative braking can return energy, but only when the system is designed for it. The U.S. Department of Energy’s motor-system guidance stresses proper sizing, controls, and heat management as key efficiency practices. One detail is often missed: low-speed operation may reduce cooling. Recheck thermal limits there. A perfect selection rarely survives the first hot summer. That is worth admitting before installation.